Less diver dependence
Move more of the inspection burden to a controlled robotic platform.
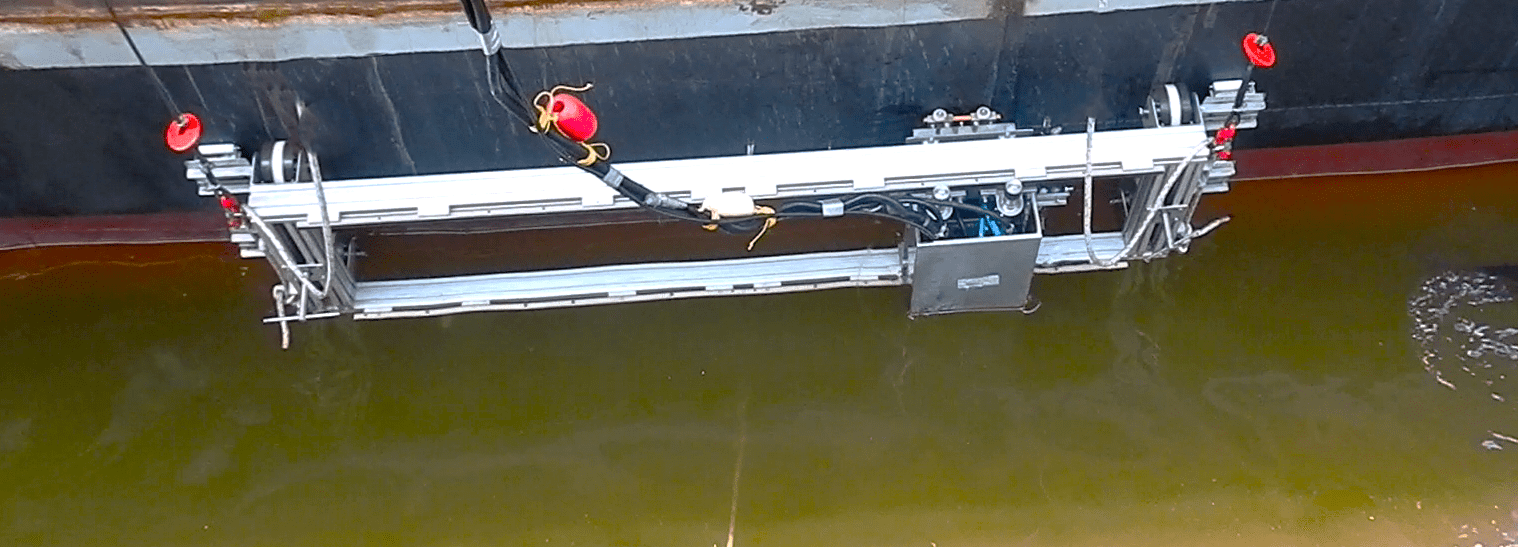
Mag-Rover robotic hull survey
Mag-Rover is an indigenously developed magnetic robotic crawler that combines high-end visual inspection, grid-based ultrasonic scanning and TFET response for comprehensive in-water hull condition assessment.
Asset challenge
Traditional in-water hull surveys depend heavily on visual interpretation and diver access. Mag-Rover combines three complementary evidence types—visual testing, ultrasonic thickness mapping and TFET—to reduce the chance that a single method misses an important condition.
Inspection architecture
Select an evidence layer to see how it contributes to the inspection decision.
Specialized camera hardware, lighting, water-displacement technique and image processing improve visibility of the hull surface.
Coverage & decision
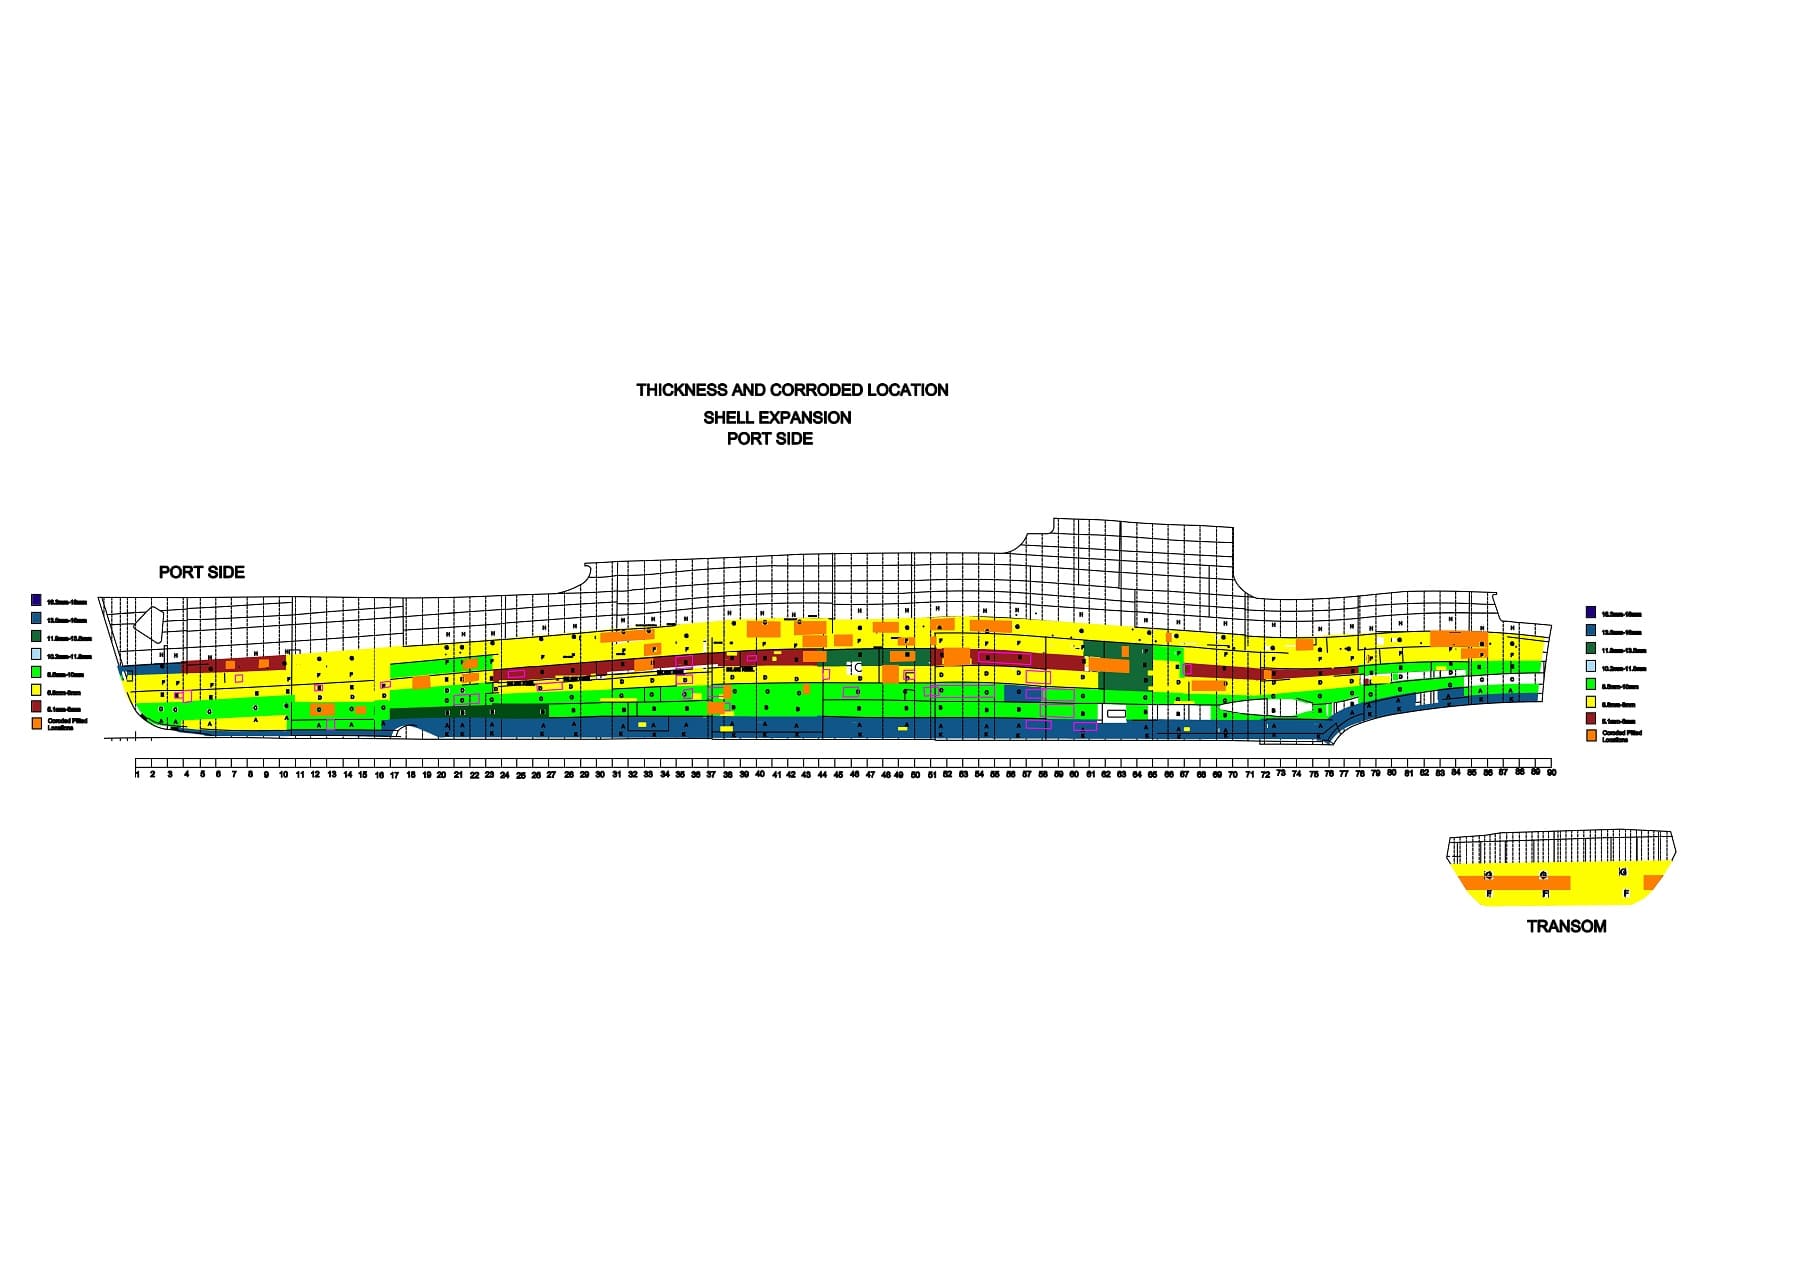
The combination of VT, UT and TFET provides surface condition, absolute thickness and early electromagnetic response in one survey workflow, supporting more confident maintenance and class-related decision making.
Field evidence
The imagery below is sourced from the original NDT Technologies service material and presented in a new evidence-led layout.
Engineering outcomes
The value is not the sensor alone—it is the quality, coverage and usability of the evidence it produces.
Move more of the inspection burden to a controlled robotic platform.
Systematic UT scanning improves coverage compared with isolated spot measurements.
TFET adds information before corrosion or stress becomes visually obvious.
Structured grid data supports repeatable location and future comparison.